About
Founder-led mechatronics engineering.
AlpineLab Mechatronics designs robots and actuators for demanding applications, combining research-grade engineering with the pragmatism needed to reach production.
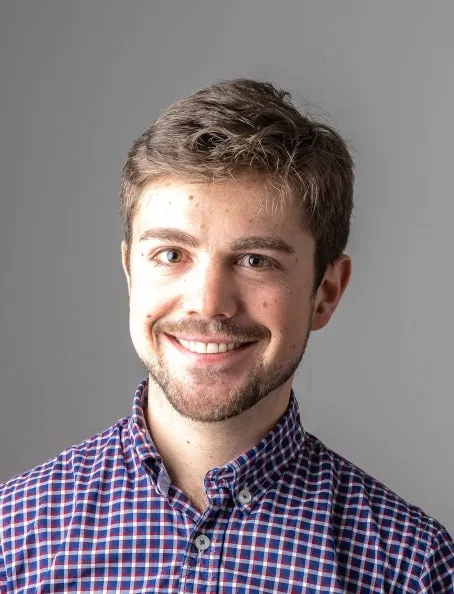
Founder
François Heremans
Founder · Dr. Engineer in Robotics
François founded AlpineLab Mechatronics in 2022 to bring advanced mechatronic design to companies building robots and actuators for demanding applications.
He holds a PhD in electromechanical engineering from UCLouvain, Belgium (2019). Funded by an F.R.S.-FNRS grant, his thesis covered the design and validation of a lightweight, low-energy robotic ankle prosthesis, the origin of ELSA. He previously graduated summa cum laude from the École Polytechnique de Louvain (2015), where his work on humanoid robot balance received the prize for the best master thesis.
He then spent a year at the University of Edinburgh's Institute of Perception, Action and Behaviour, led the electromechanical design of an assistive exoskeleton at EPFL's REHAssist laboratory in Lausanne, and was lead mechanical engineer on an indoor inspection drone at Flybotix. From 2020 to 2024, he led the improvement and technology transfer of the ELSA prosthesis in collaboration with Össur.
Through AlpineLab, he covers the full chain of mechatronic development: mechanical design, actuators and electronics, embedded software and control. He works in French, English and German.
Awards
- 2024Best Poster Award (1st place) · IEEE BioRob 2024, HeidelbergLocking mechanism for the ELSA ankle prosthesis
- 2016Best Paper Award (2nd place) · IEEE BioRob 2016, SingaporeMaster thesis work on humanoid robot balance
- 2015AILouvain/Decoux Innovation Prize · École Polytechnique de LouvainBest master thesis of the year
How we work
What you can expect.
Engineering rigour
Decisions backed by models, simulation and measurement, and written down so they can be reviewed.
End-to-end ownership
From the first sizing to the hand-off to production, the same engineer is accountable for the whole system.
Transparency
Clear phases, honest risk assessment and no surprises on cost or schedule.
Discretion
Client projects stay confidential, and nothing is shown publicly without written approval.
Research
Selected publications.
- 2025ELSA: A Foot-Size Powered Prosthesis Reproducing Ankle Dynamics During Various Locomotion Tasks
F. Heremans, J. Evrard, D. Langlois and R. Ronsse
IEEE Transactions on Robotics, vol. 41, pp. 415–429
- 2024A Lightweight and Compact Lockable Parallel Spring Enhances the Performance of a Powered Ankle-Foot Prosthesis
F. Heremans, J. Evrard, D. Langlois and R. Ronsse
IEEE RAS/EMBS International Conference on Biomedical Robotics and Biomechatronics (BioRob), pp. 407–412
- 2019Bio-inspired Design and Validation of the Efficient Lockable Spring Ankle (ELSA) Prosthesis
F. Heremans, S. Vijayakumar, M. Bouri, B. Dehez and R. Ronsse
IEEE International Conference on Rehabilitation Robotics (ICORR), pp. 411–416
- 2017Design of an Energy Efficient Transfemoral Prosthesis Using Lockable Parallel Springs and Electrical Energy Transfer
F. Heremans and R. Ronsse
IEEE International Conference on Rehabilitation Robotics (ICORR), pp. 1305–1312
Based in Switzerland
Swiss engineering, global reach.
AlpineLab Mechatronics is based in Bex, in the Vaud Alps, close to Lausanne and the Lake Geneva region, and works with clients across the globe, on site when it matters and remotely the rest of the time.
For manufacturing, assembly and certification testing, we rely on a network of trusted suppliers and specialists, while remaining your single point of contact.
Have a mechatronic challenge?
Tell us about your project. We are happy to sign an NDA before any technical discussion.