Project — Medical robotics
ELSA powered ankle prosthesis
A powered ankle prosthesis that delivers 150 Nm in a foot-sized package weighing 1.2 kg, designed by AlpineLab from a blank sheet to small-series production.
- Total weight
- 1.2 kg
- Ankle torque
- 150 Nm
- Envelope
- Foot-sized
Challenge
An ankle prosthesis has to deliver the torque of a human ankle at every step, yet stay light enough to wear all day and small enough to fit inside a shoe. Powered prostheses usually trade one of these against the others.
Approach
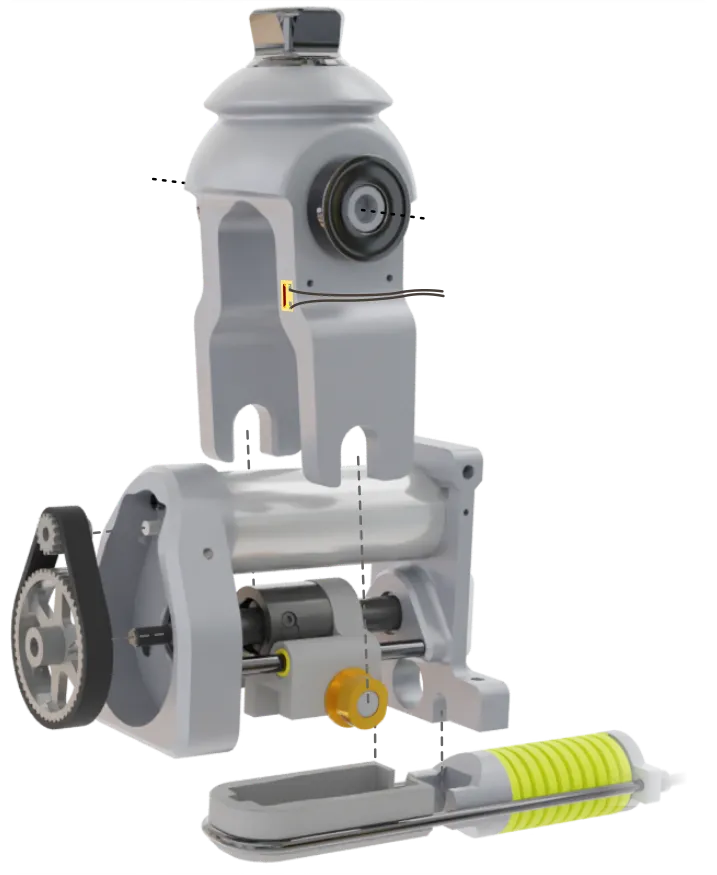
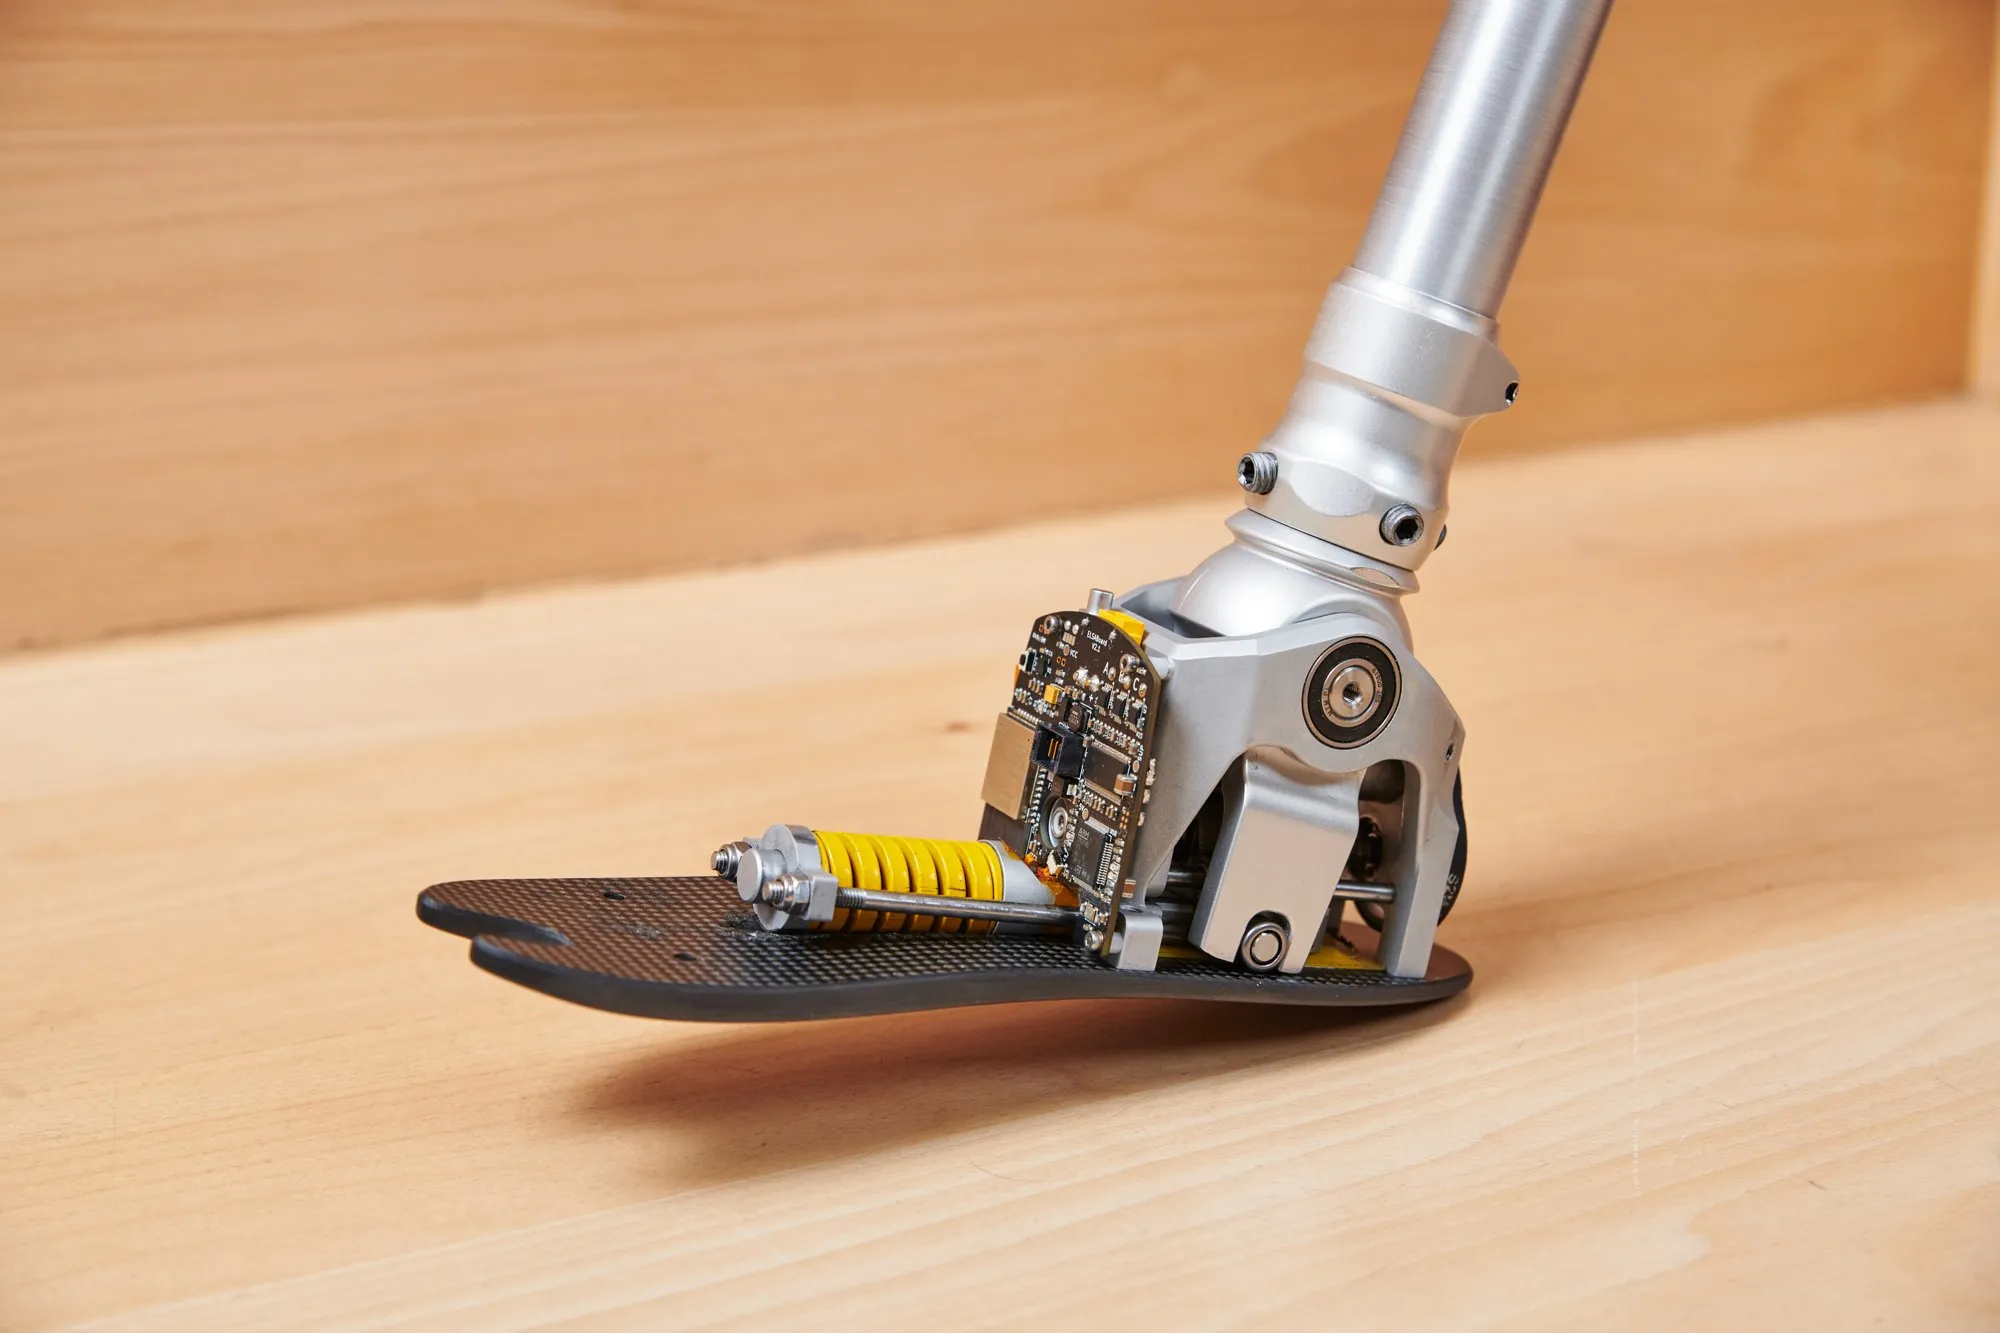
AlpineLab designed ELSA from a blank sheet: actuator, transmission, structure, electronics and control. The motor drives the ankle through a belt and screw transmission. A spring mechanism in parallel with the actuator assists it during the step and disengages automatically at toe-off, while the main actuator continues the push-off. The electronics are integrated within the foot.
Custom dashboard
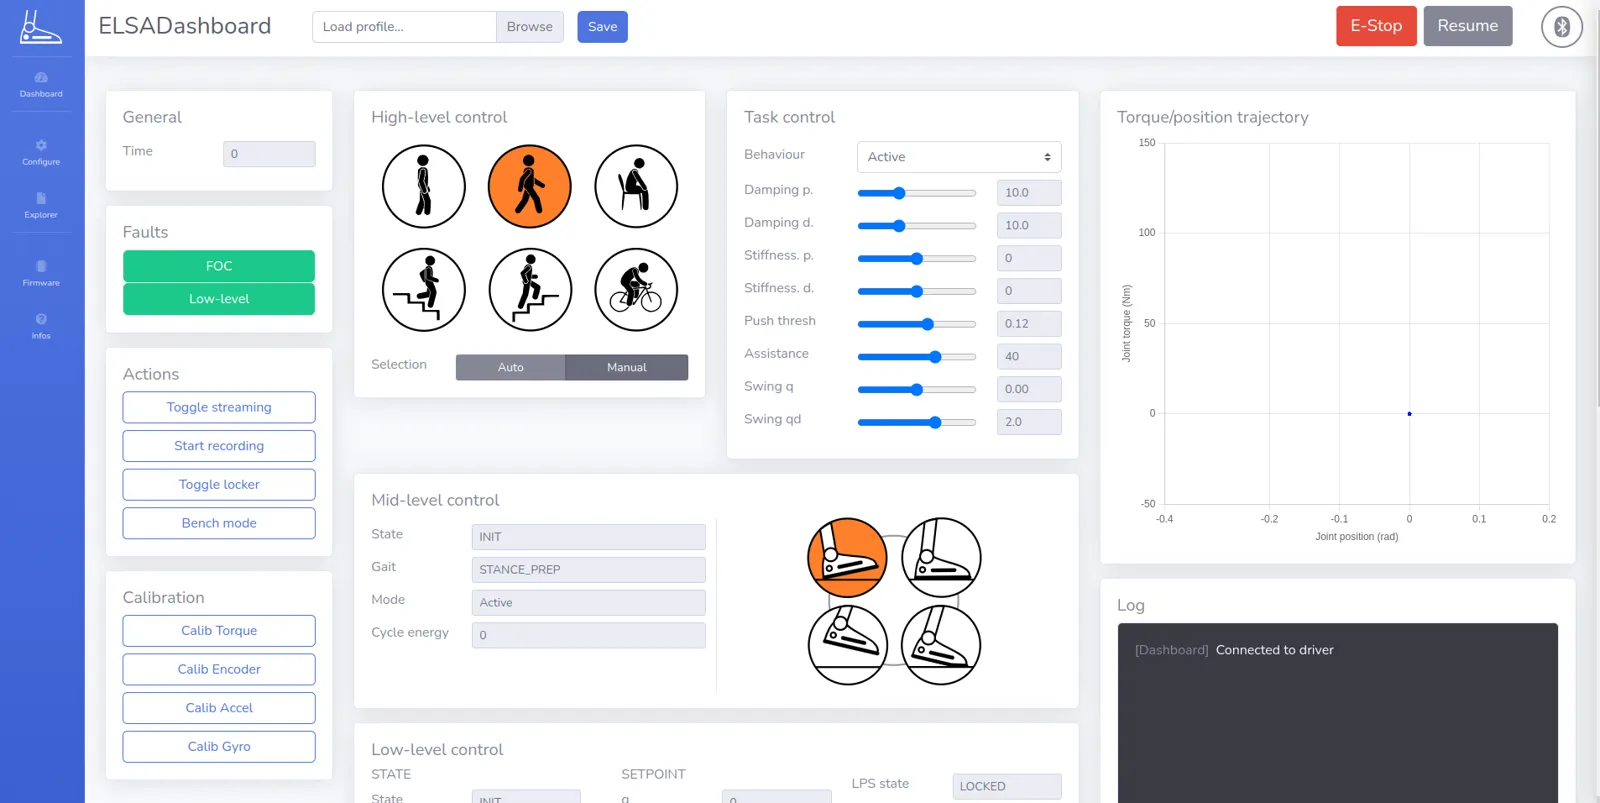
To interact with the device, AlpineLab also developed a dedicated dashboard that connects to the prosthesis over Bluetooth. It lets clinicians and engineers:
- select the activity mode (standing, walking, sitting, stairs, cycling), automatically or manually
- tune the controller live, such as stiffness, damping, push-off threshold and assistance level, and save the settings as user profiles
- follow the gait phase and controller state in real time, with a live torque/position plot
- stream and record data for analysis
- calibrate the torque sensor, encoder and inertial sensors
- monitor faults and stop the device instantly with an emergency stop
Result
ELSA delivers 150 Nm of ankle torque for a total weight of 1.2 kg, all within the volume of a foot. The design was taken through to small-series production.
Publication
The design and validation of ELSA are published in IEEE Transactions on Robotics:
F. Heremans, J. Evrard, D. Langlois and R. Ronsse, “ELSA: A Foot-Size Powered Prosthesis Reproducing Ankle Dynamics During Various Locomotion Tasks,” IEEE Transactions on Robotics, vol. 41, pp. 415–429, 2025. doi:10.1109/TRO.2024.3508314
Have a mechatronic challenge?
Tell us about your project. We are happy to sign an NDA before any technical discussion.